 中文
 英文
 俄文
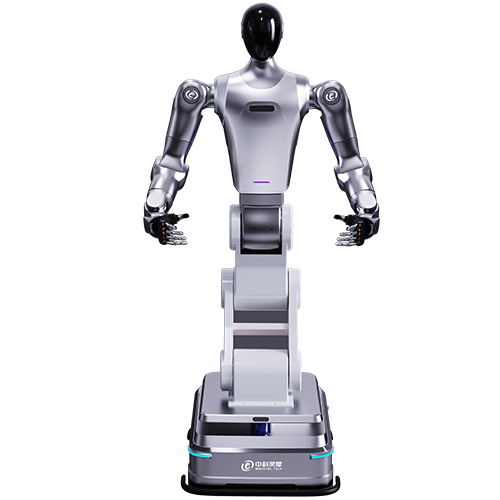
The LSRobot-002 is designed for industrial scenarios requiring both mobility and fine manipulation. Its omnidirectional chassis navigates tight spaces, while dual 6-DoF arms coordinate to perform switchgear operation, gripping, and transfer tasks. Vision positioning and force feedback ensure precision and reliability. Suitable for substation inspection, chemical plant bridge operations, and multi-station transfer workflows.
|
~6h Endurance ~6h |
10kg Single Arm Payload 10kg |
|
430mm Turning Radius 430mm |
10° Climbing 10° |
|
Specification |
Value |
|
Dimensions |
1670×550×660mm (extended) |
|
Weight |
≈150kg |
|
Drive |
Differential wheeled |
|
Speed |
0-1.5m/s, adjustable |
|
Braking Distance |
<0.1m at 0.5m/s |
|
Turning Radius |
430mm |
|
Max. Climbing Angle |
10° |
|
Obstacle Clearance |
<30mm |
|
Compatible Hands |
Linkage dexterous hands |
|
Total DoF |
4+7+7 (excluding hands) |
|
Single Arm DoF |
7 |
|
Single Arm Payload |
10kg |
|
Perception |
Vision, force-tactile |
|
Battery |
48V 40AH |
|
Charging |
Wired |
|
Endurance |
≈6h at 0.5m/s on flat terrain |
|
Communication |
Wi-Fi |
|
Wrist DoF (Optional) |
2 (custom) |
| Agile Mobility | Dual-Arm Coordination |
| Long Endurance |
Omnidirectional Chassis |