 中文
 英文
 俄文
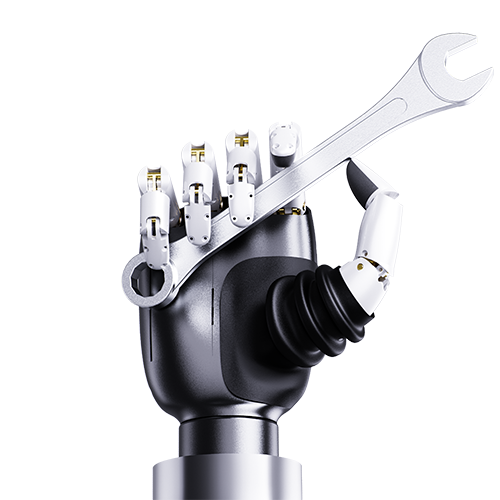
The LGT-601 is a low-temperature optimized variant of the LG-601, validated in lab testing at -40°C. Suitable for cold-chain automation, sub-zero research projects, and other low-temperature scenarios where standard dexterous hands cannot operate.
|
-40℃ Operating Temperature -40°C |
20kg Static Load 20kg |
|
5mm Min. Grasp 5mm |
<100ms Response Speed |
|
Specification |
Value |
|
Active DoF |
6 |
|
Passive DoF |
10 |
|
Single Finger Tip Force |
3N |
|
Grip Force |
10N |
|
Static Load |
20kg |
|
Repeatability |
3mm |
|
Finger Speed |
360°/s |
|
Finger Flexion Angle |
≥90° |
|
Min. Graspable Object |
5mm |
|
Communication |
CAN |
|
Operating Voltage |
DC12V±10% |
|
Static Current |
0.25A@12V |
|
No-Load Average Current |
0.15A@12V |
|
Max Current |
5A@12V |
|
Min. Operating Temperature |
-40°C |
|
Force Sensor (Optional) |
Up to 7 channels (5 fingertips + 1 palm + 1 six-axis), 0.1N resolution |
|
Wrist DoF (Optional) |
2 (custom) |
| Stable in Extreme Cold | Low-Temperature Reliabilit |
| Heavy-Duty Endurance | Rapid Deployment |